Wound³ Inc. · Jan 2022 – Apr 2026
Automated 3D-capture accuracy rig (modified CNC, then AR4 robotic arm)
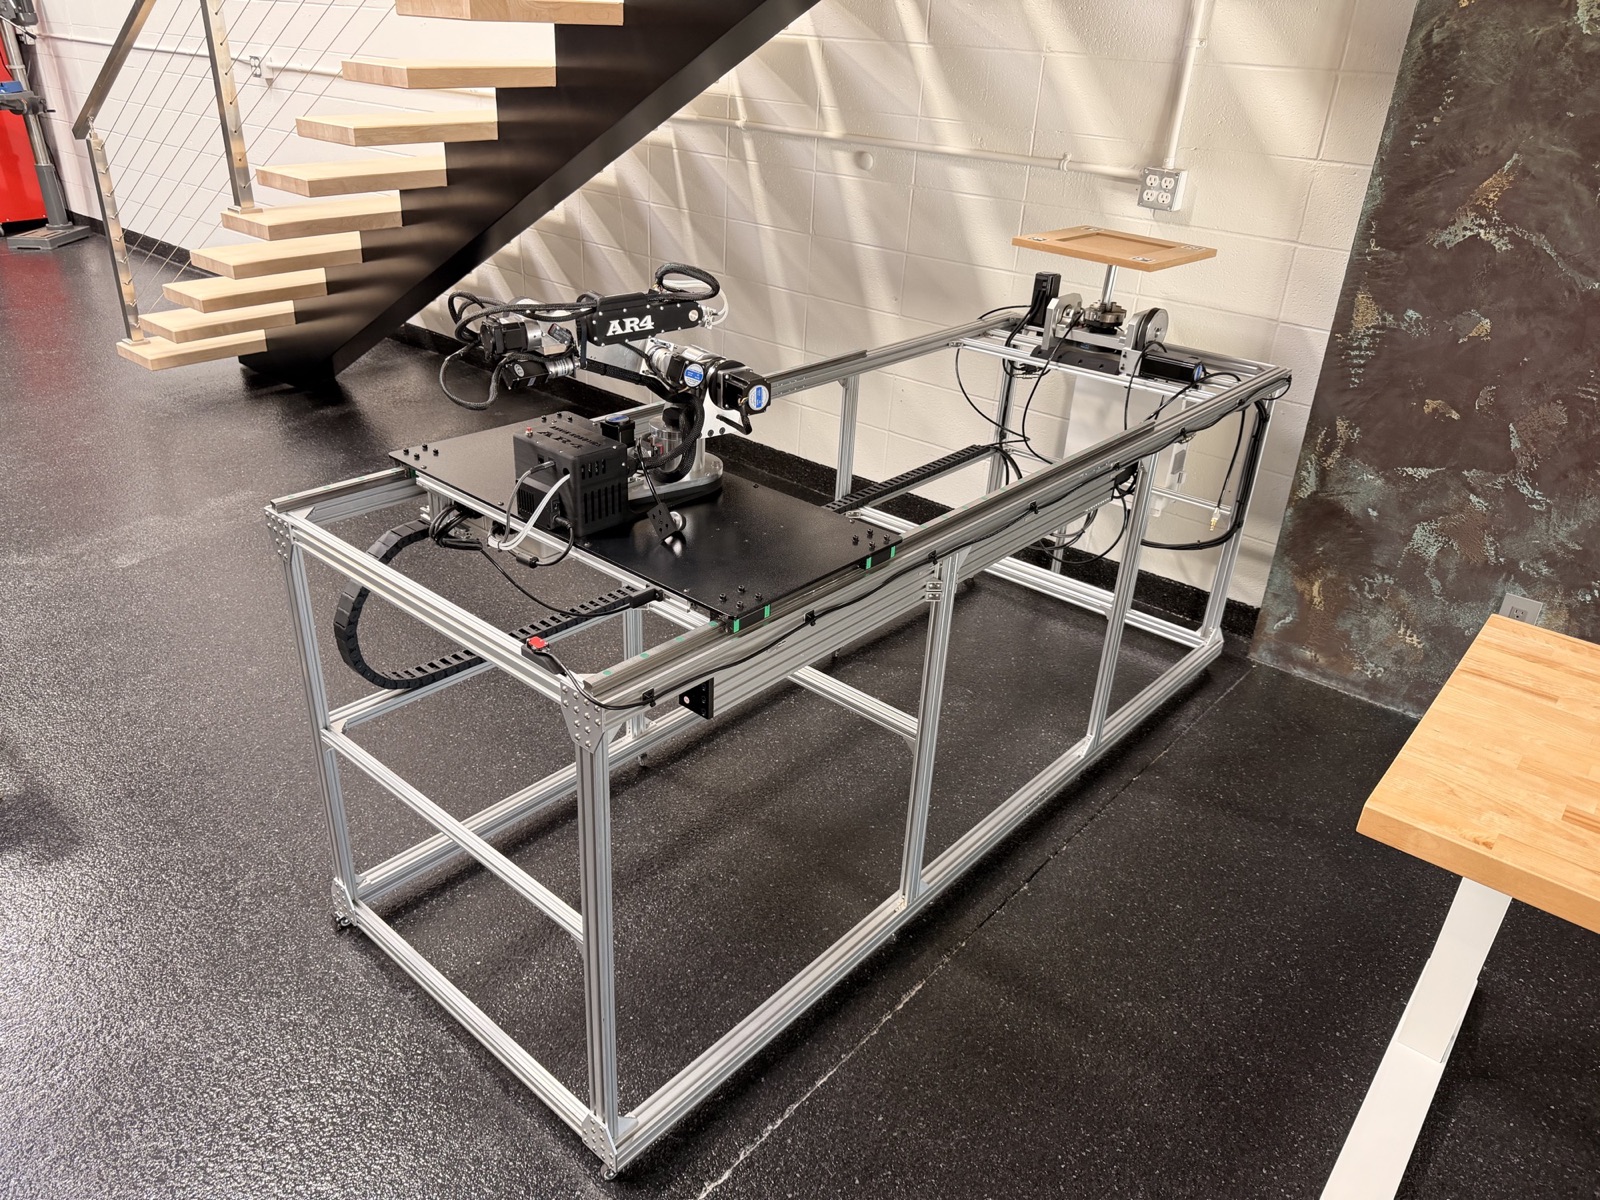
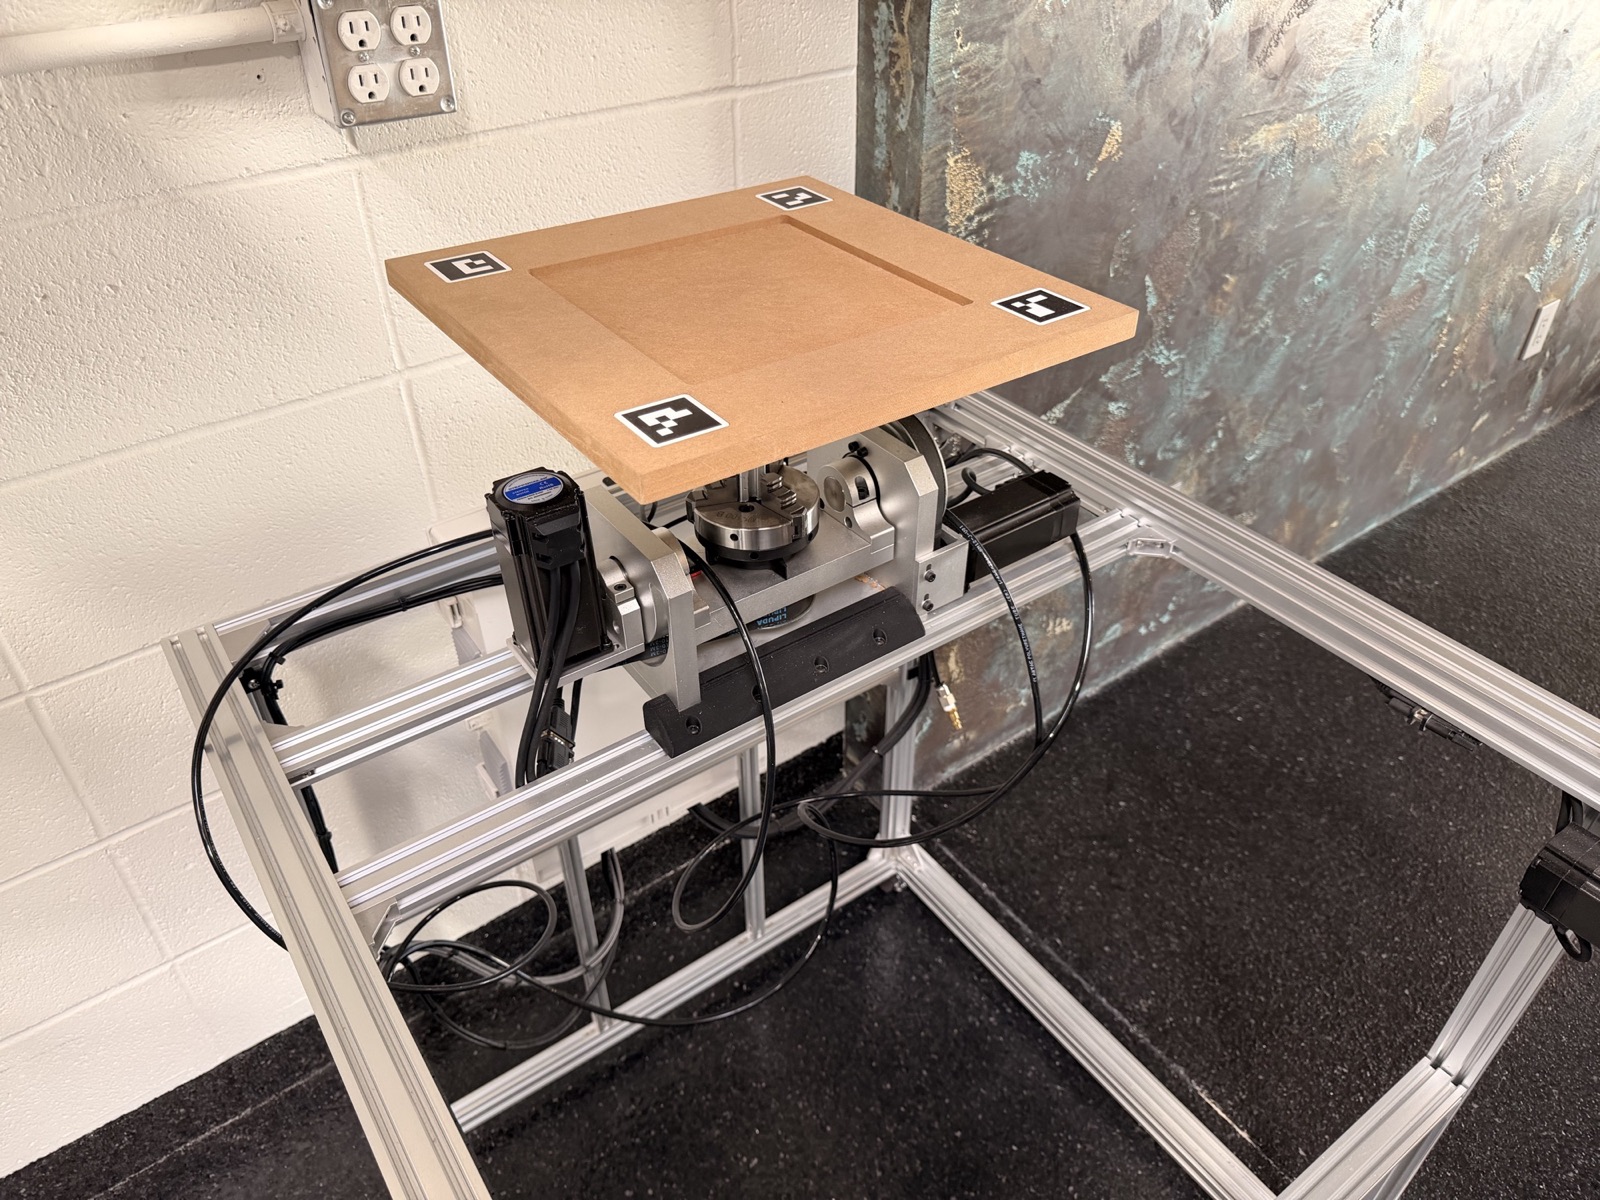
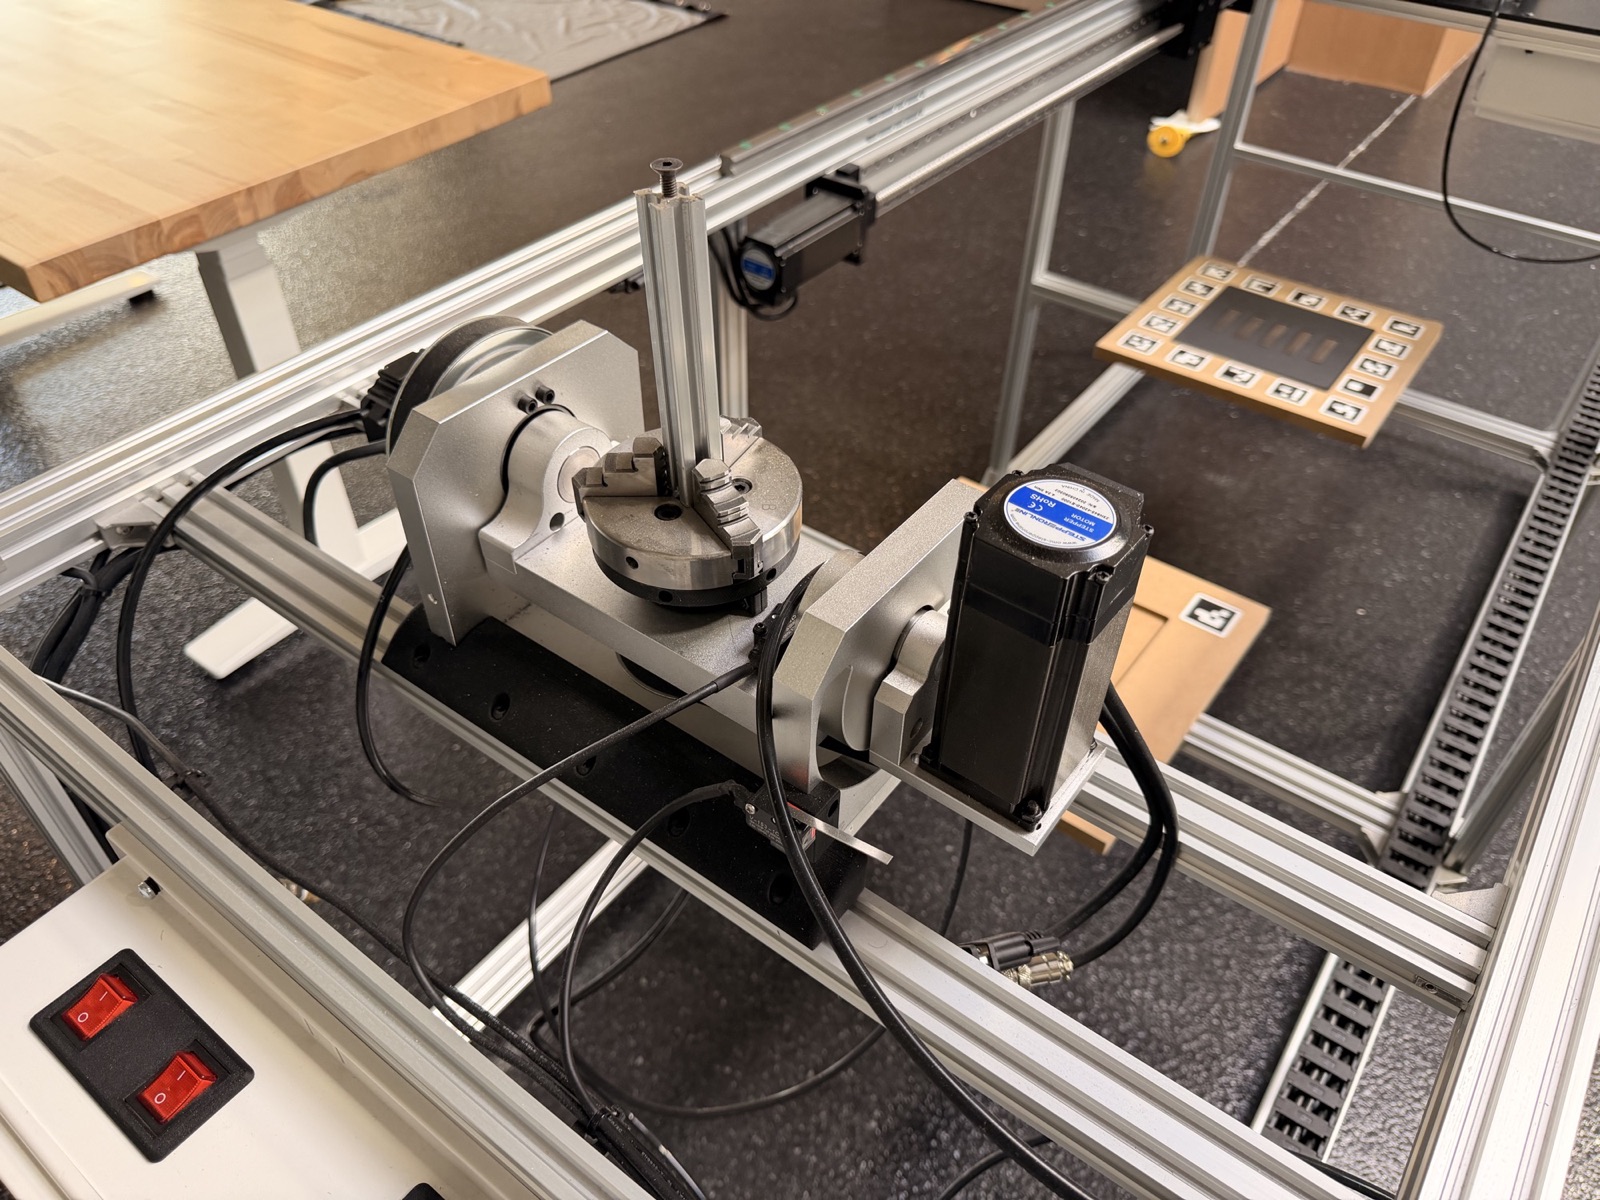
Automated test rig for measuring how 3D-model accuracy varies with capture distance and phone sensor generation, by scanning objects of known size at programmed positions. The robotic-arm version was my mechanical engineering capstone project.
My role: Designed and built the rig, its control box and phone clamp, and wrote the sequencing and trigger software.
Highlights
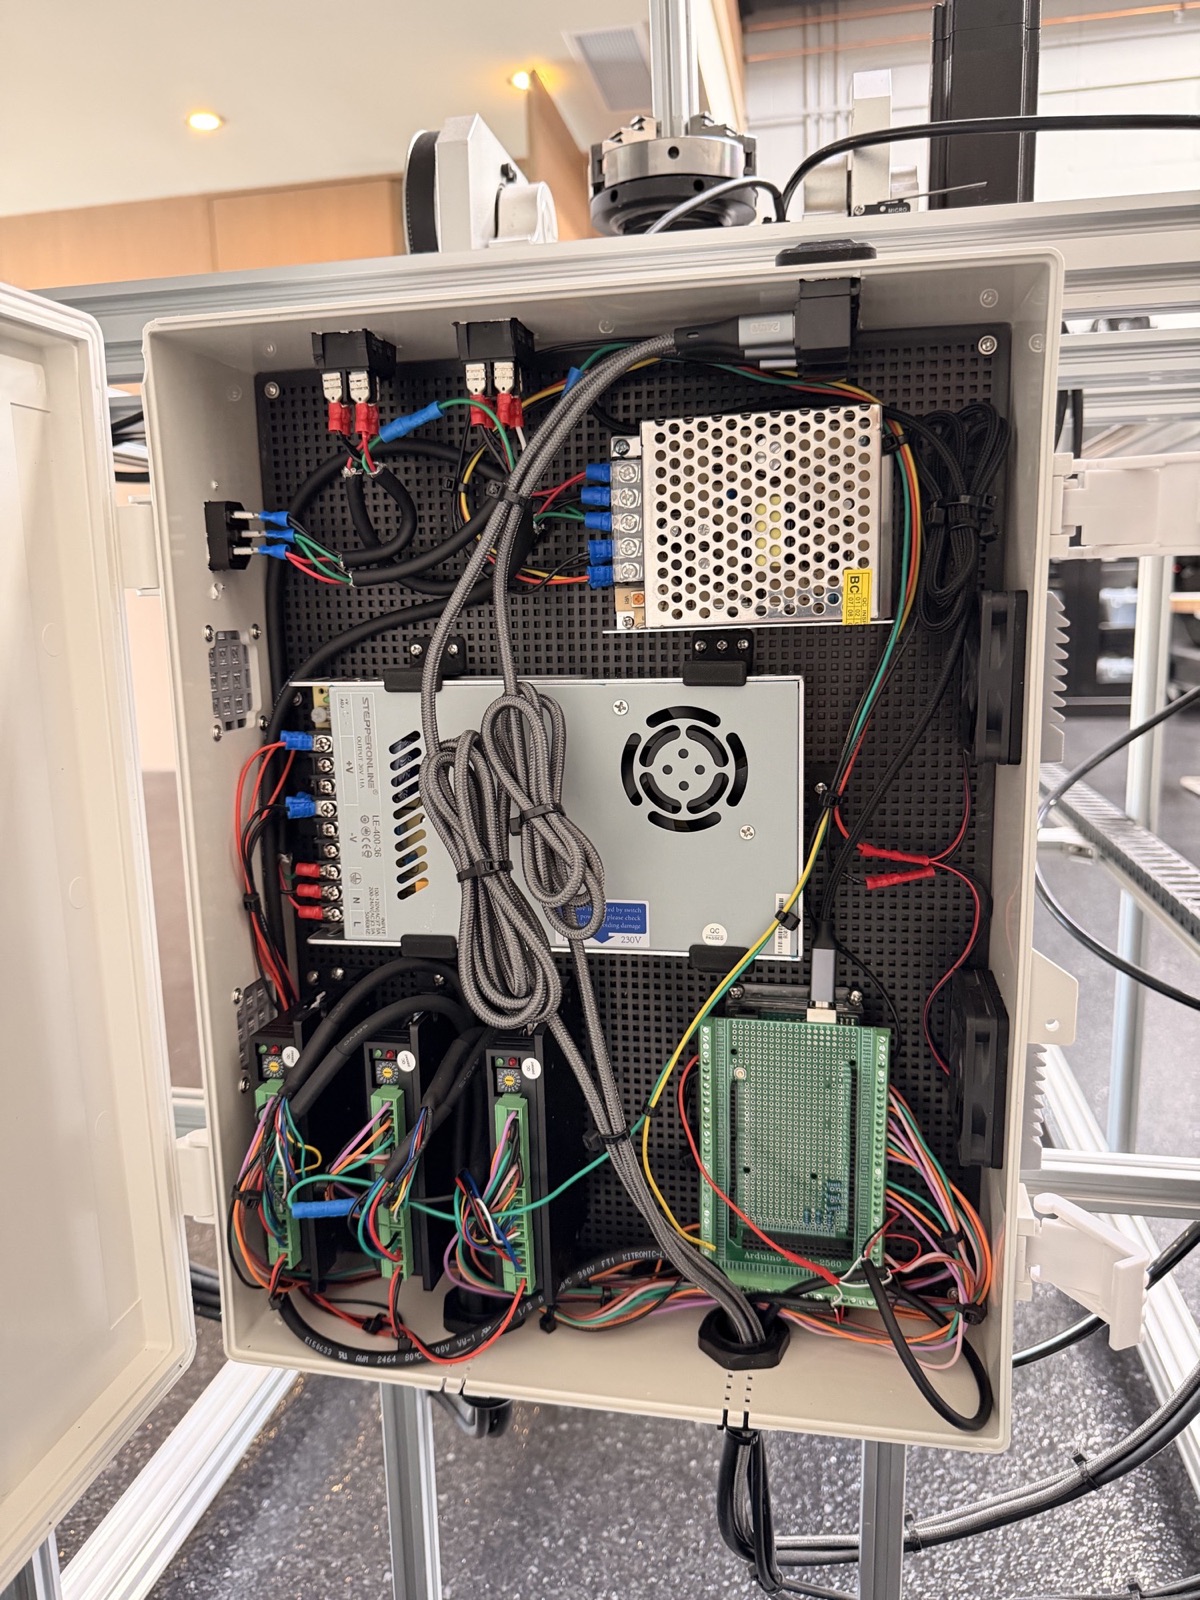
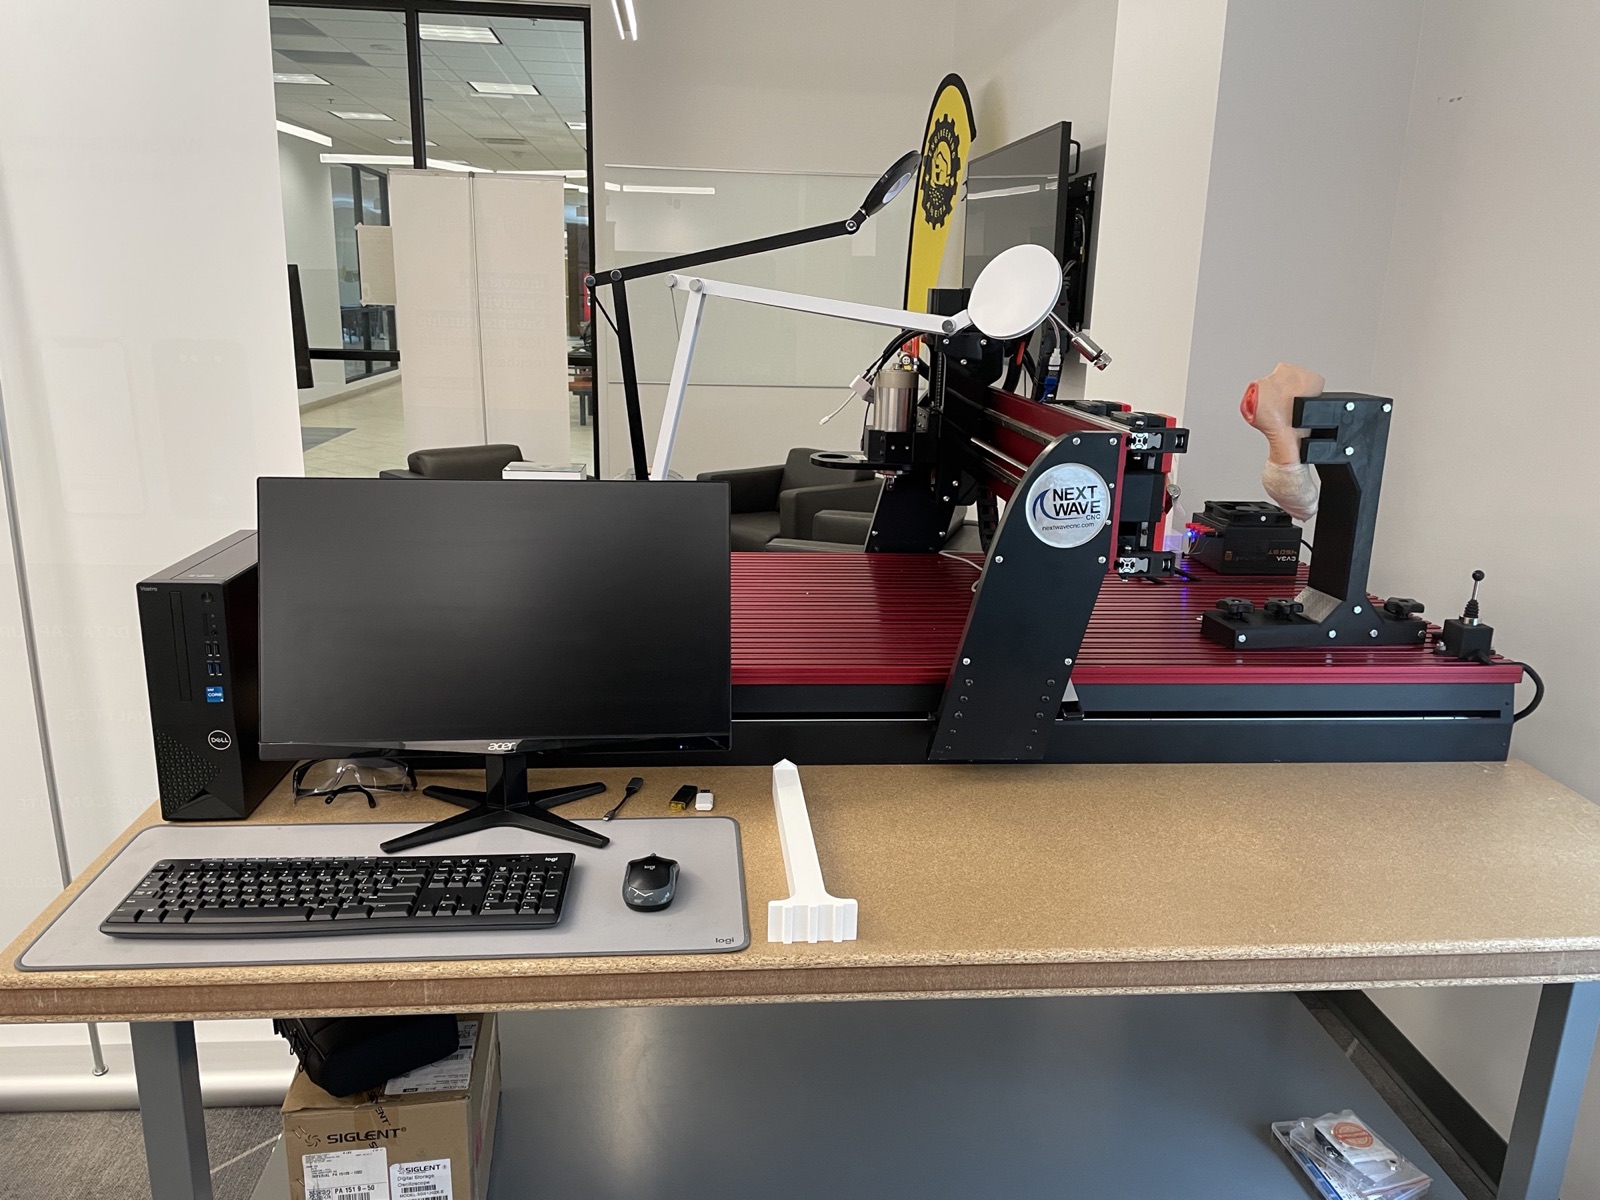
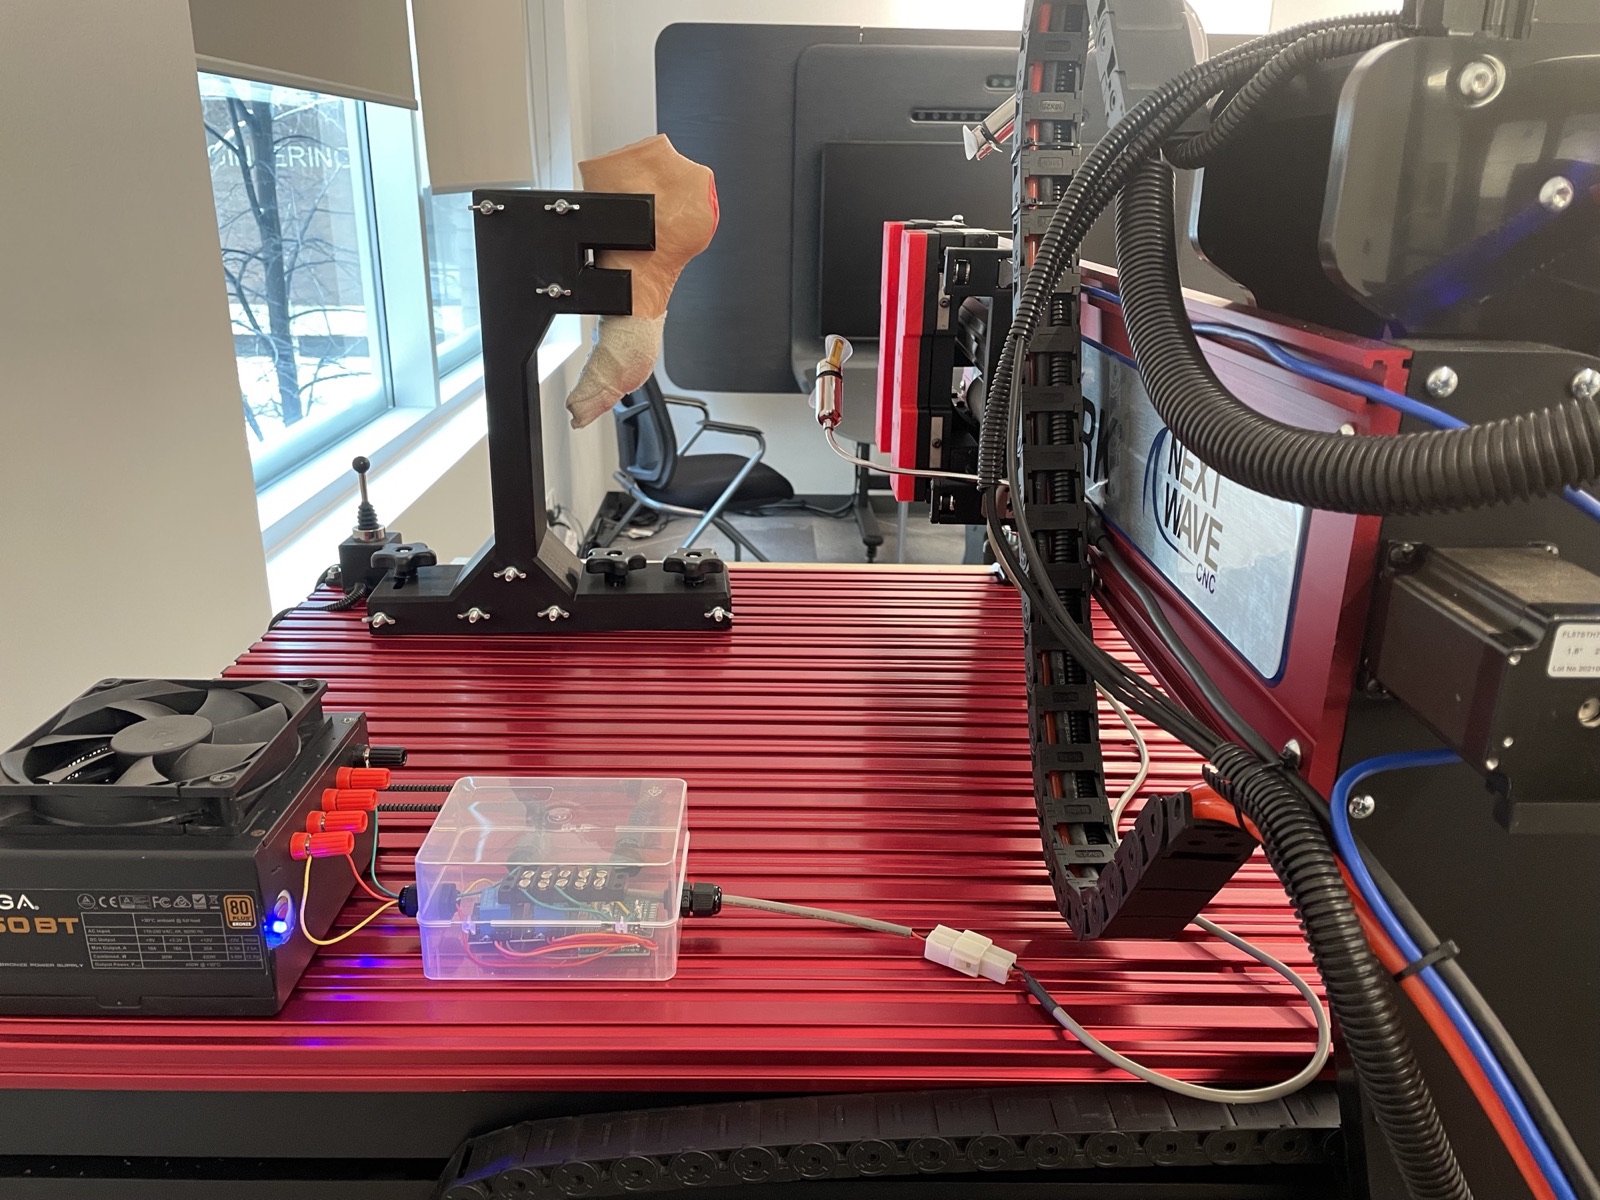
- Built an automated capture-accuracy rig from a modified CNC: designed an alignment clamp to hold an iPhone on the gantry, built a control box that converted the CNC's spindle-on output into an aux trigger for the phone, and wrote the G-code sequencing so scans ran at a series of distances.
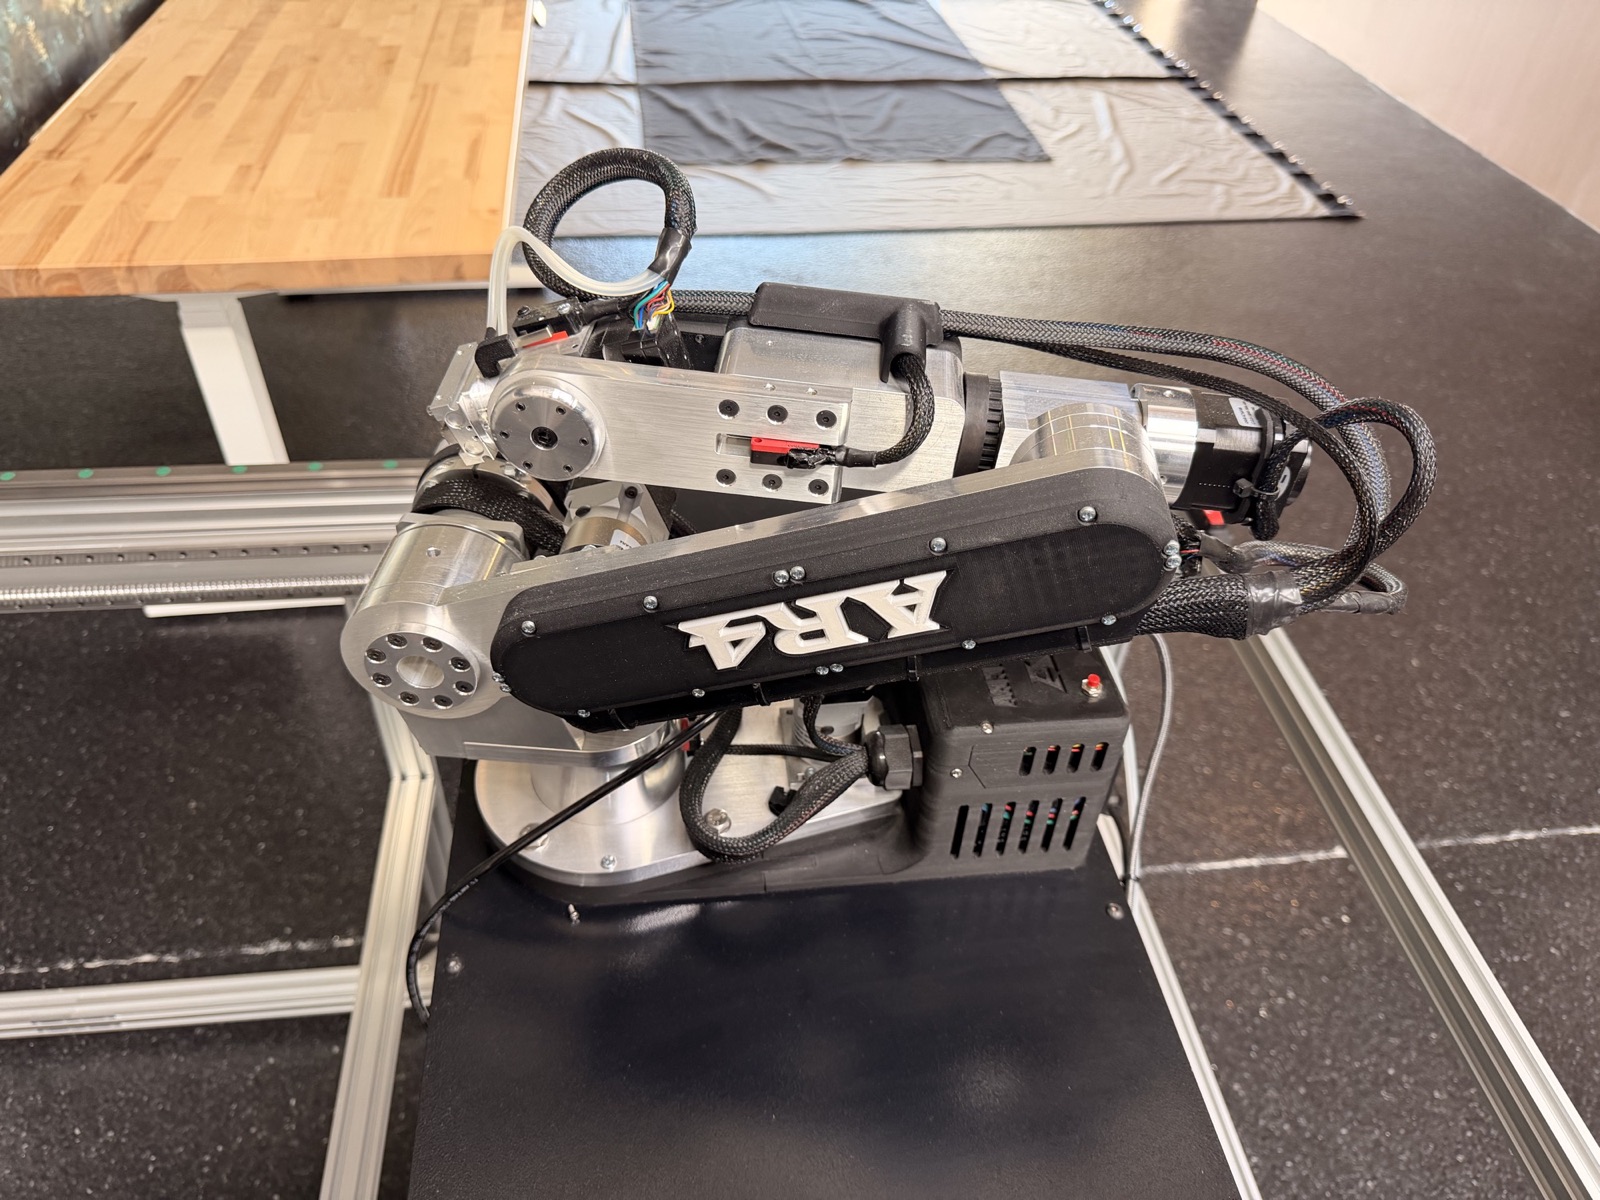
- Replaced the CNC rig with an AR4 robotic arm, coordinating arm moves and capture sequences over WebSockets; this automated capture system was my mechanical engineering capstone project.
- Characterized 3D-model accuracy against objects of known size across phone generations with stereo, LiDAR, and TrueDepth sensors, and scanned and modelled limbs and wounds as test subjects.
My contribution
I designed the system in Fusion 360, then built and wired it. Version one was a modified CNC router: I designed an alignment clamp to locate the iPhone on the gantry, built a control box that converted the CNC's spindle-on command into a capture trigger for the phone, and wrote software that stepped the machine through a sequence of positions in G-code while the test app captured a scan at each. Version two replaced the CNC with an AR4 robotic arm, with motion and capture sequencing coordinated over WebSockets.
Technical details
The rig measured how model accuracy varies with capture distance, using reference objects of known size and iPhones from several generations to compare stereo, LiDAR, and TrueDepth sensing.
Tools and processes
- Processes
- CAD in Fusion 360; control-box wiring; G-code motion sequencing; WebSocket coordination
- Tools
- Fusion 360; CNC router (modified); AR4 robotic arm; iPhones with stereo; LiDAR; and TrueDepth sensors
Part of Wound³ Inc. (Fabri Sciences Inc.).